Skip to content

About

I build legged robots and the control behind them. Pick a part.

I am a control engineer who works on robots: legged machines, a hexapod built for power-grid maintenance, and swarms of unmanned ground vehicles.

It started with hardware. My degree is in electrical and electronics engineering, and my first published work was a hexapod for inspecting power-system components.

The robots change, and the control problem stays the same: sense the machine, estimate its state, decide, and drive the actuators.

I am doing a PhD in control and instrumentation, and alongside it I take client work building software and data pipelines.

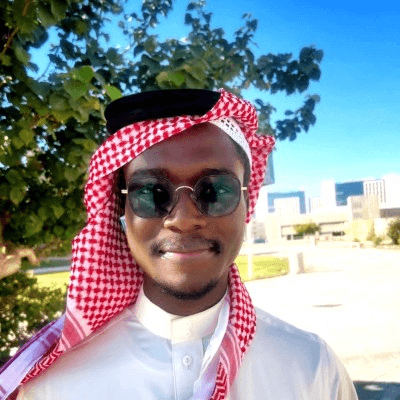
Abdurrahman Aderinto, portrait
Dhahran, Saudi Arabia · UTC+3

Background

Education

B.Eng. Electrical & Electronics Engineering

Air Force Institute of Technology, Kaduna, Nigeria · 2018 – 2023

GPA 4.73 / 5.00. Best graduating student, Electrical & Electronics Engineering. Coursework ran through control theory, control engineering, signals and systems, reliability engineering, and neural networks.

Instrumentation

Embedded systems at NCAIR

National Centre for Artificial Intelligence and Robotics · 2022 - 2023

A heart-rate monitoring system for pregnant women, AVR architecture down to the ATmega328P, and research on a low-cost rover for weed management and irrigation. Later onboarded incoming interns onto the same hardware.

Research

Telemetry robotics for power-system surveillance

e-Prime (Scopus Q1), 2024 · ICEIT 2023

A hexapod system built to inspect power-system components without sending a person to them. Published as a journal article and a conference paper, both co-authored.

Both papers, with citations

Practice

Production applications and data work

Python · TypeScript · C++ · MATLAB

Frontend engineering on shipped products, and the data side of the same problem: readings and exports moved off equipment and into tables a team can query.

Doctorate

PhD research in robotics and control

KFUPM - Control & Instrumentation · In progress

Control for legged robots, hexapods and swarms of unmanned ground vehicles: how a controller keeps a machine, or a group of them, doing what the plan says.

Closing the loop on every kind of robot.

Sense, estimate, decide, actuate, on legs and on wheels.

Based in
Dhahran, Saudi Arabia · UTC+3
Availability
Open to consulting work and research collaboration